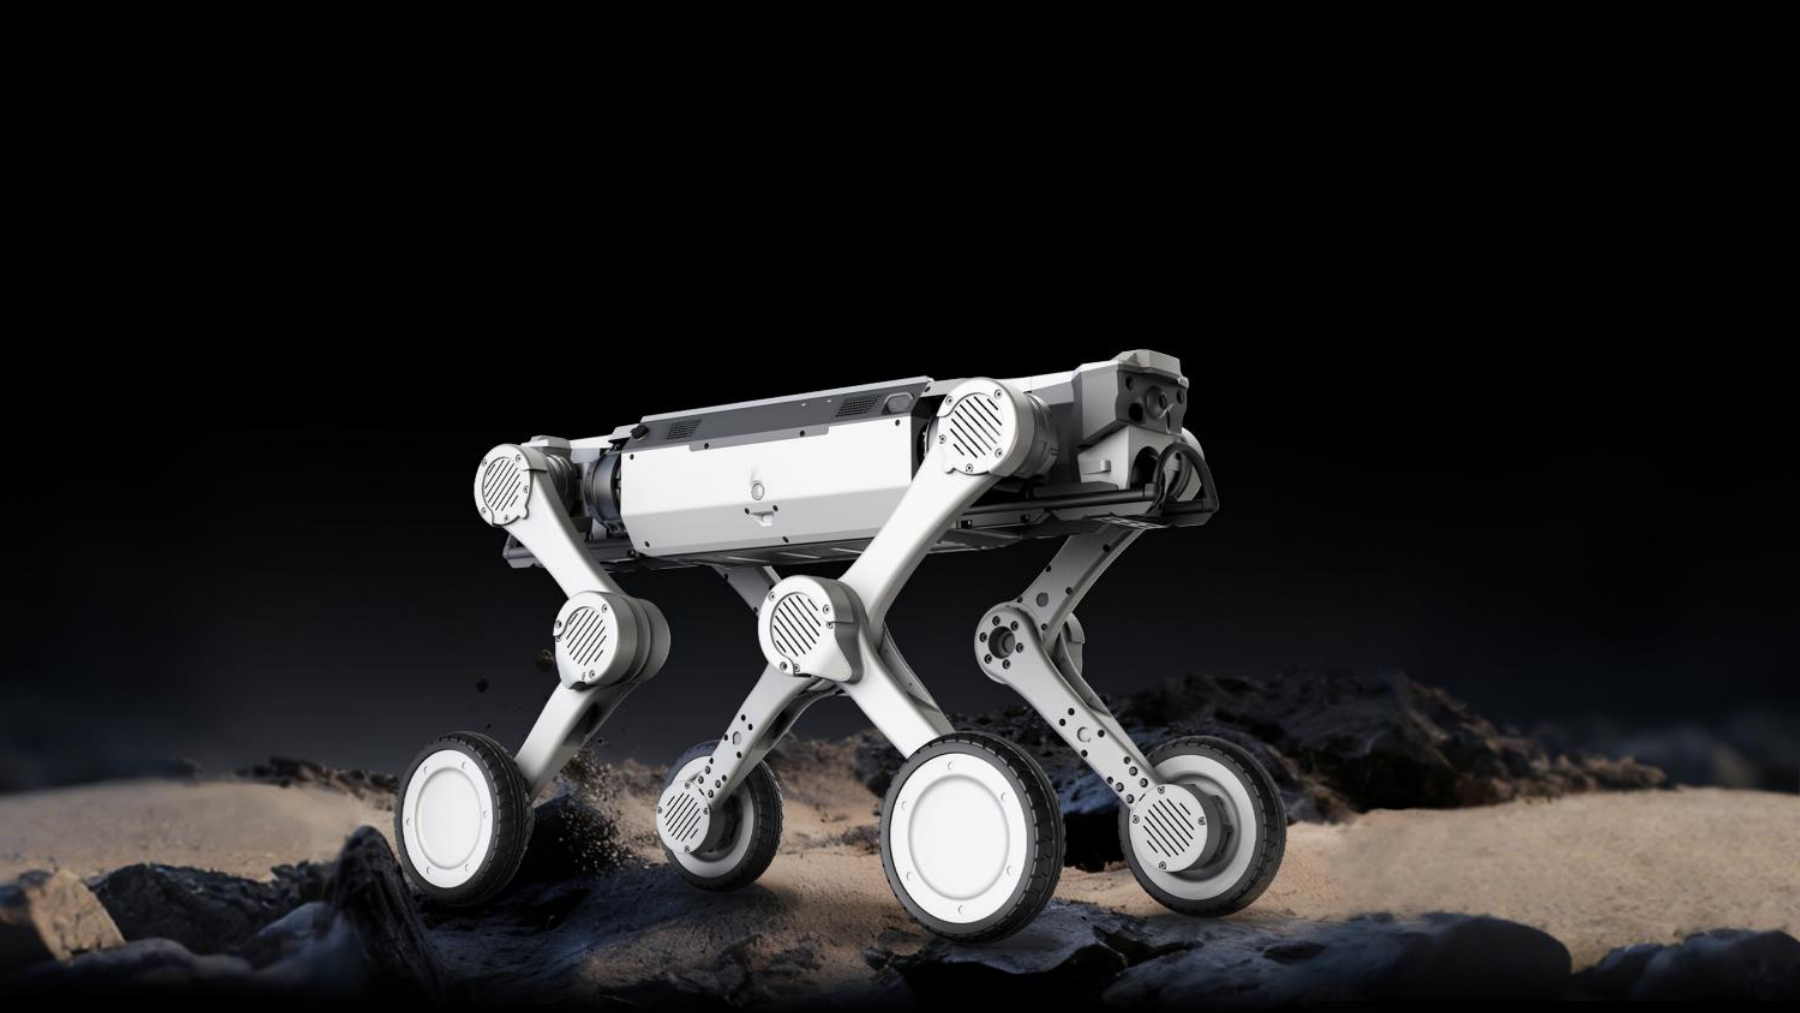
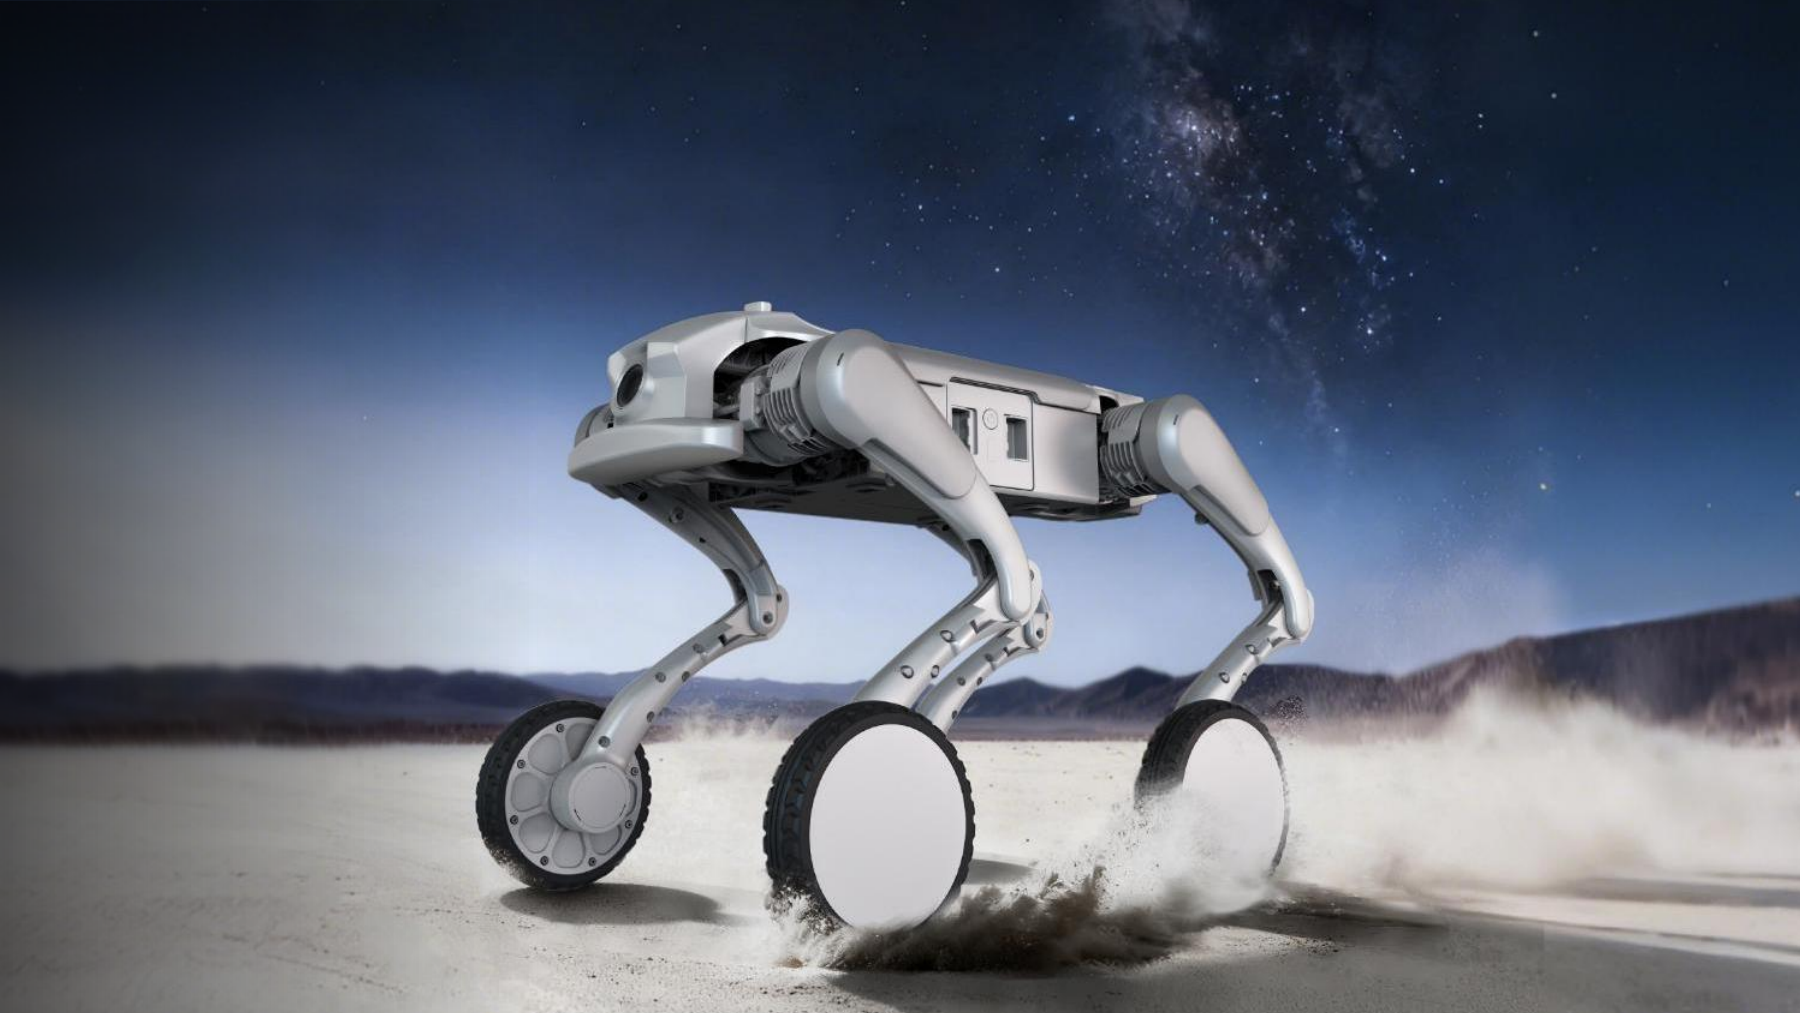
Wheeled-legged quadruped robot crossing a desert at night
Embodied AI · Full-stack robotics

Embodied IntelligenceProduct Portfolio

Industrial quadrupeds, wheeled-legged platforms, humanoid systems and high power-density joint modules — engineered end to end, from core component design to scaled deployment.

Solid Foundations · Pioneering the Future
2023Founded, focused on embodied intelligence
70%Of the team in R&D engineering
60%Master's degree or above
100%In-house: components, robot bodies, control stack
Company

A full-chain technology loop, built on a domestic core

Founded in 2023 and dedicated to embodied intelligence, we have built a closed technology loop — domestic core technology, full-chain capability — covering core component R&D, complete robot manufacturing and scenario deployment.

World-class team

Top-tier research talent paired with seasoned engineering experts. 70% of the team works in R&D and 60% hold a master's degree or above, with deep capability in reinforcement-learning locomotion control, VLN large models and core components.
Prototype to volume

Strong R&D combined with real mass-production experience guarantees full-cycle delivery — from technical prototype through industrialised volume manufacturing — across quadrupeds, full-size humanoids and joint modules.

Deployed and validated

Scaled deployment already underway in security patrol, power inspection and emergency rescue, with forward-looking work in mobility services and home companionship — validated by authoritative customers at home and abroad.

Product line

Four platforms, one engineering foundation

Legged agility, wheeled efficiency and industrial protection — the same joint modules, control architecture and open interfaces run through every platform.

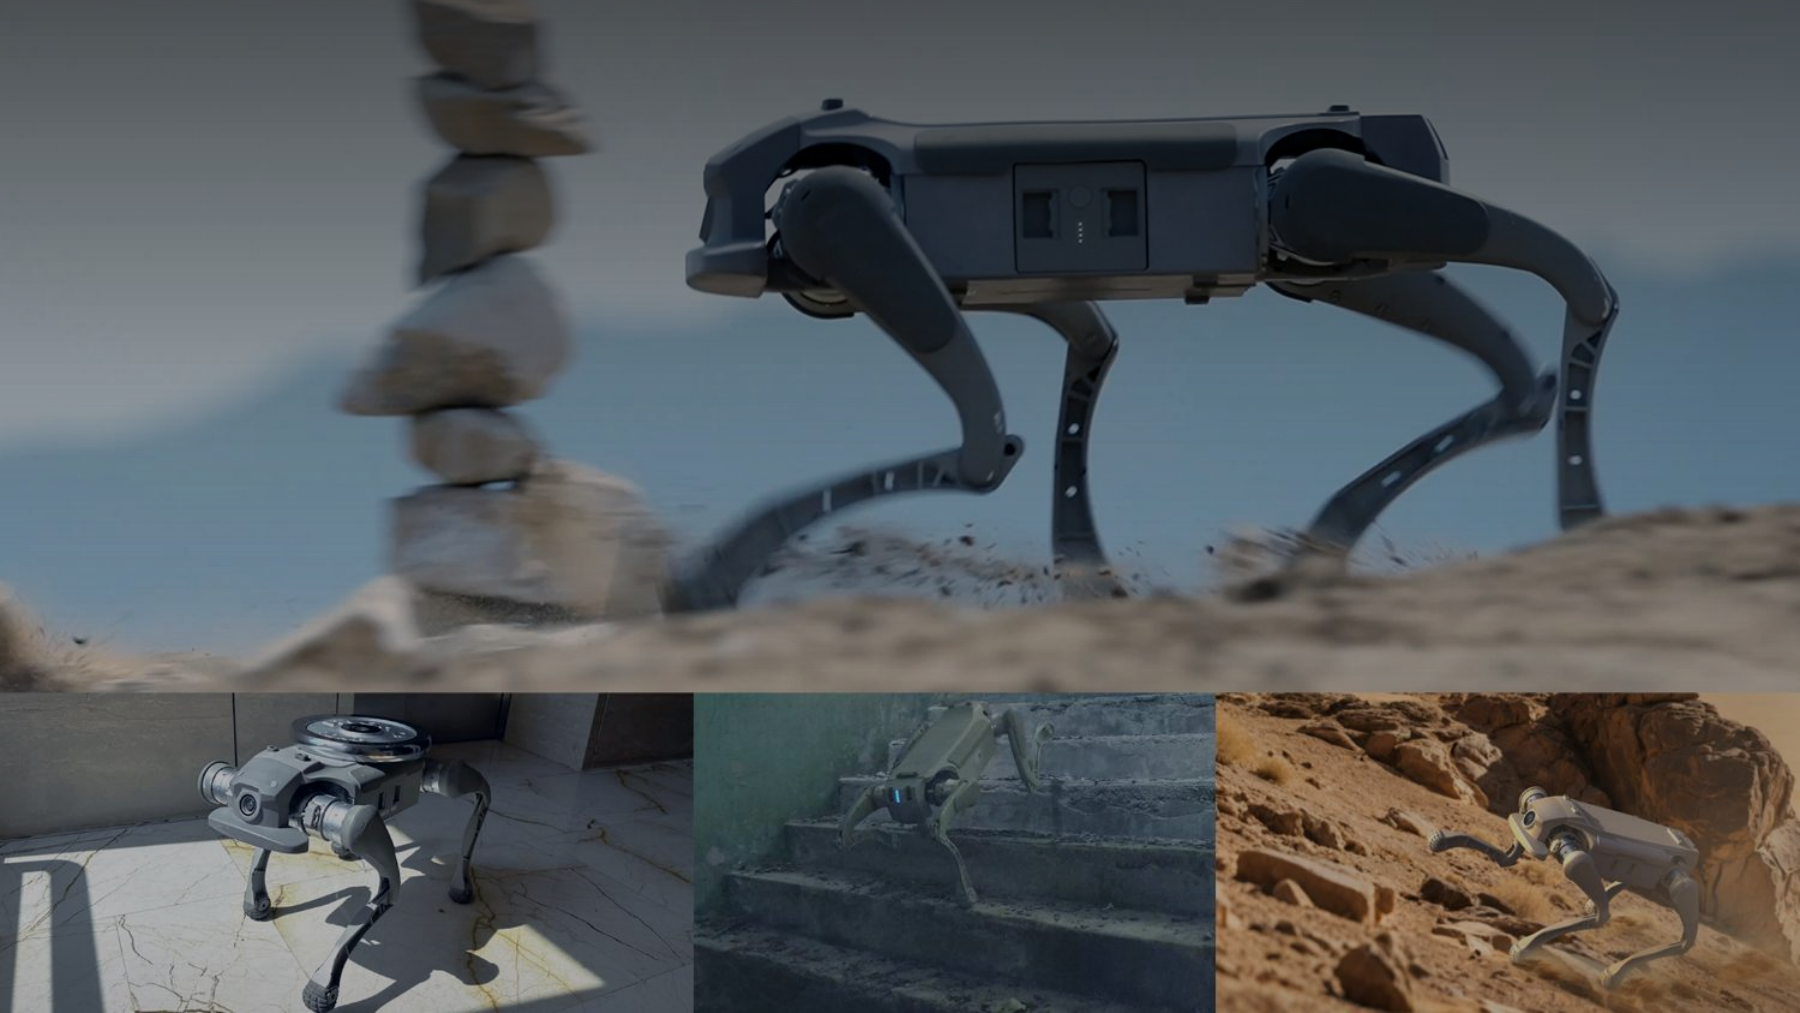
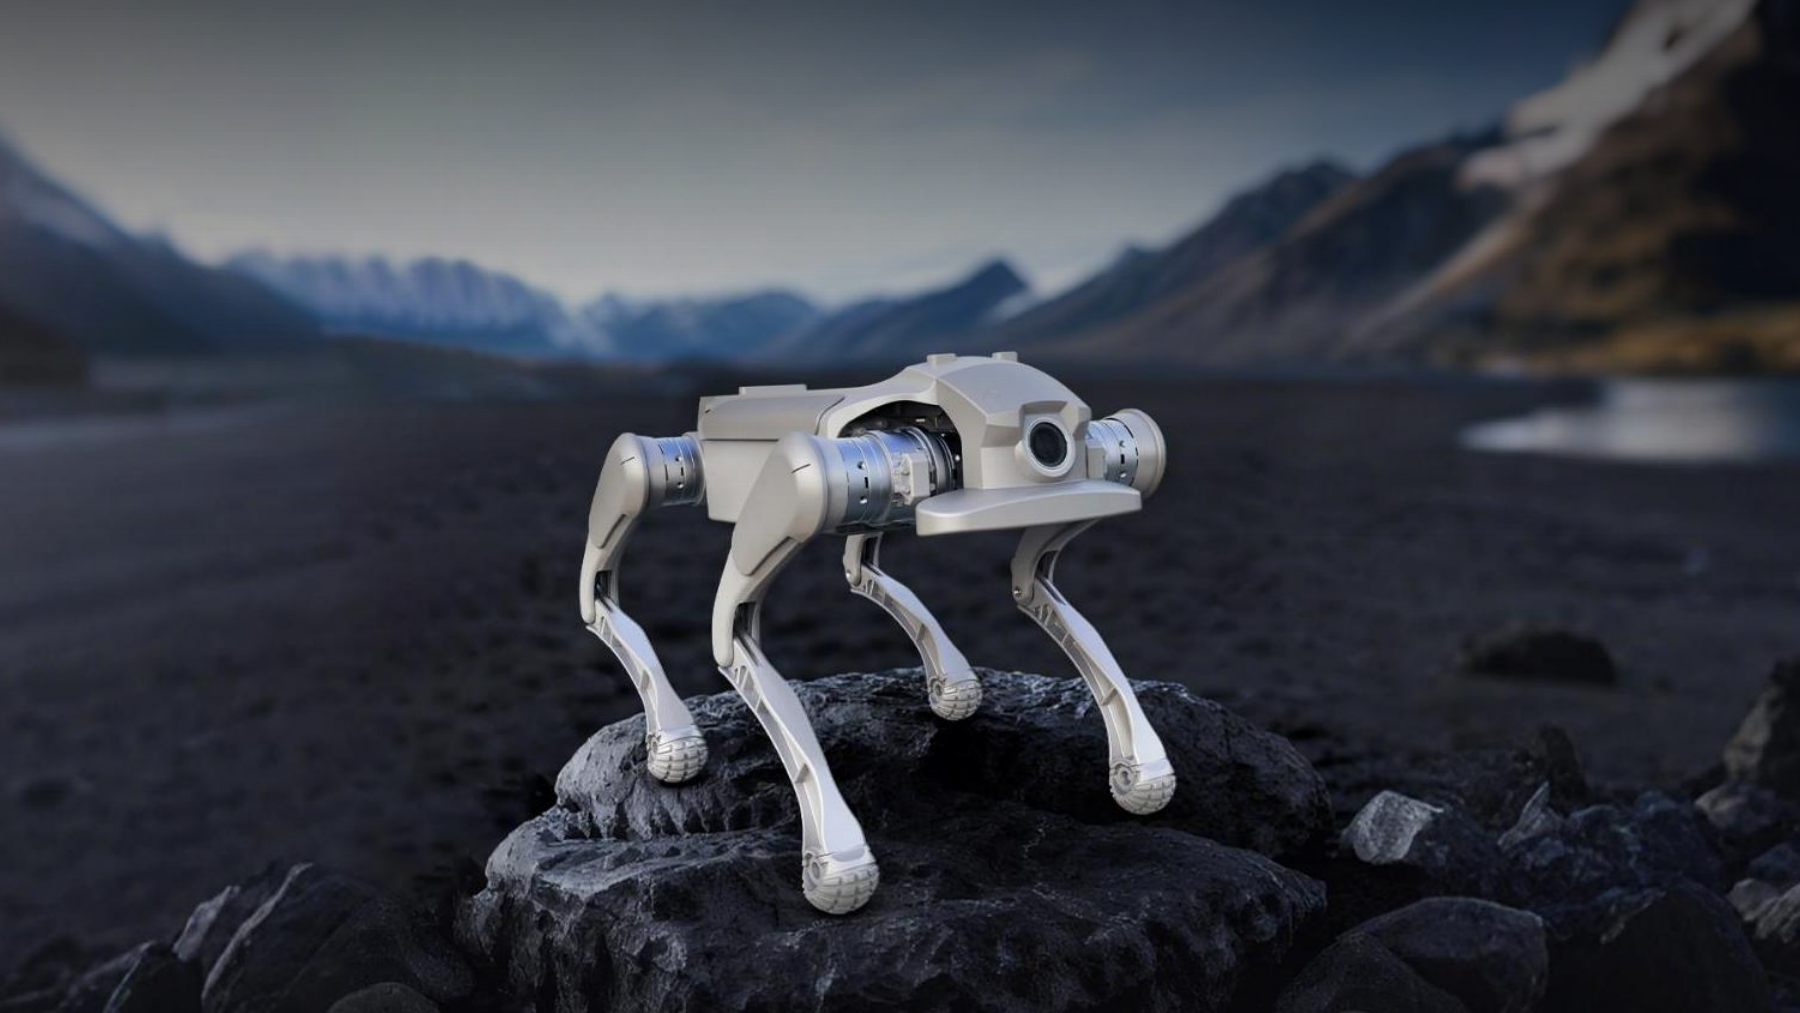
GBL01 compact industrial quadruped robot on rocky terrain
GBL01

Compact industrial quadruped robot

All-terrain, all-weather, all-protection. A high-strength frame, millisecond fall self-recovery and 360° body protection make it dependable where the work actually is.

Max speed
3.7 m/s peak 5 m/s
Max payload
8 kg peak 10 kg
Stair climb
16 cm continuous
Max slope
40°
Protection
IP54
Operating temp
0–40 °C (extreme −20 to 50 °C)
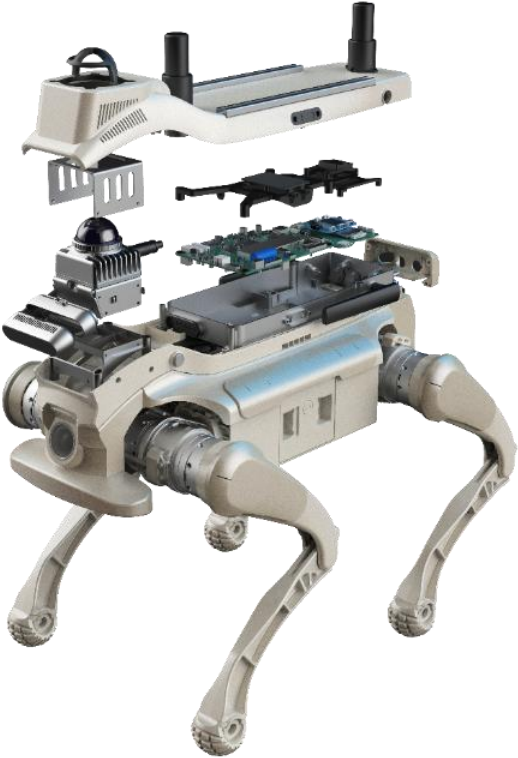
GBL01-EDU development kit, exploded view of the modular sensor and compute payload
GBL01-EDU

Development kit: full perception, true water resistance, serious compute

Purpose-built for SLAM, 3D reconstruction and embodied-AI research — indoors, outdoors, day or night.

Compute
NVIDIA Orin NX up to 100 TOPS
Depth vision
Intel RealSense
LiDAR
Livox Mid360
Fusion
RGB + depth + point cloud
Navigation
Precise mapping dynamic obstacle avoidance
Weather
IP54 indoor to outdoor
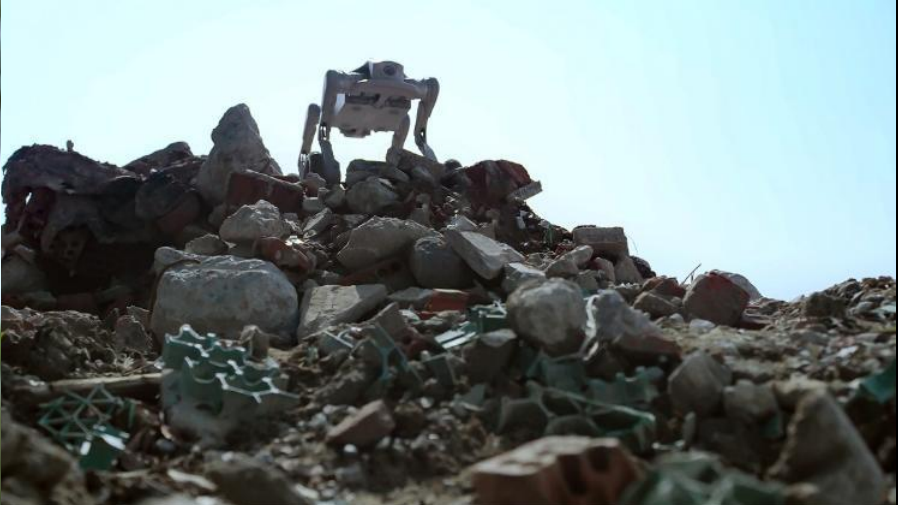
GBL01-W wheeled quadruped robot traversing a rubble pile
GBL01-W

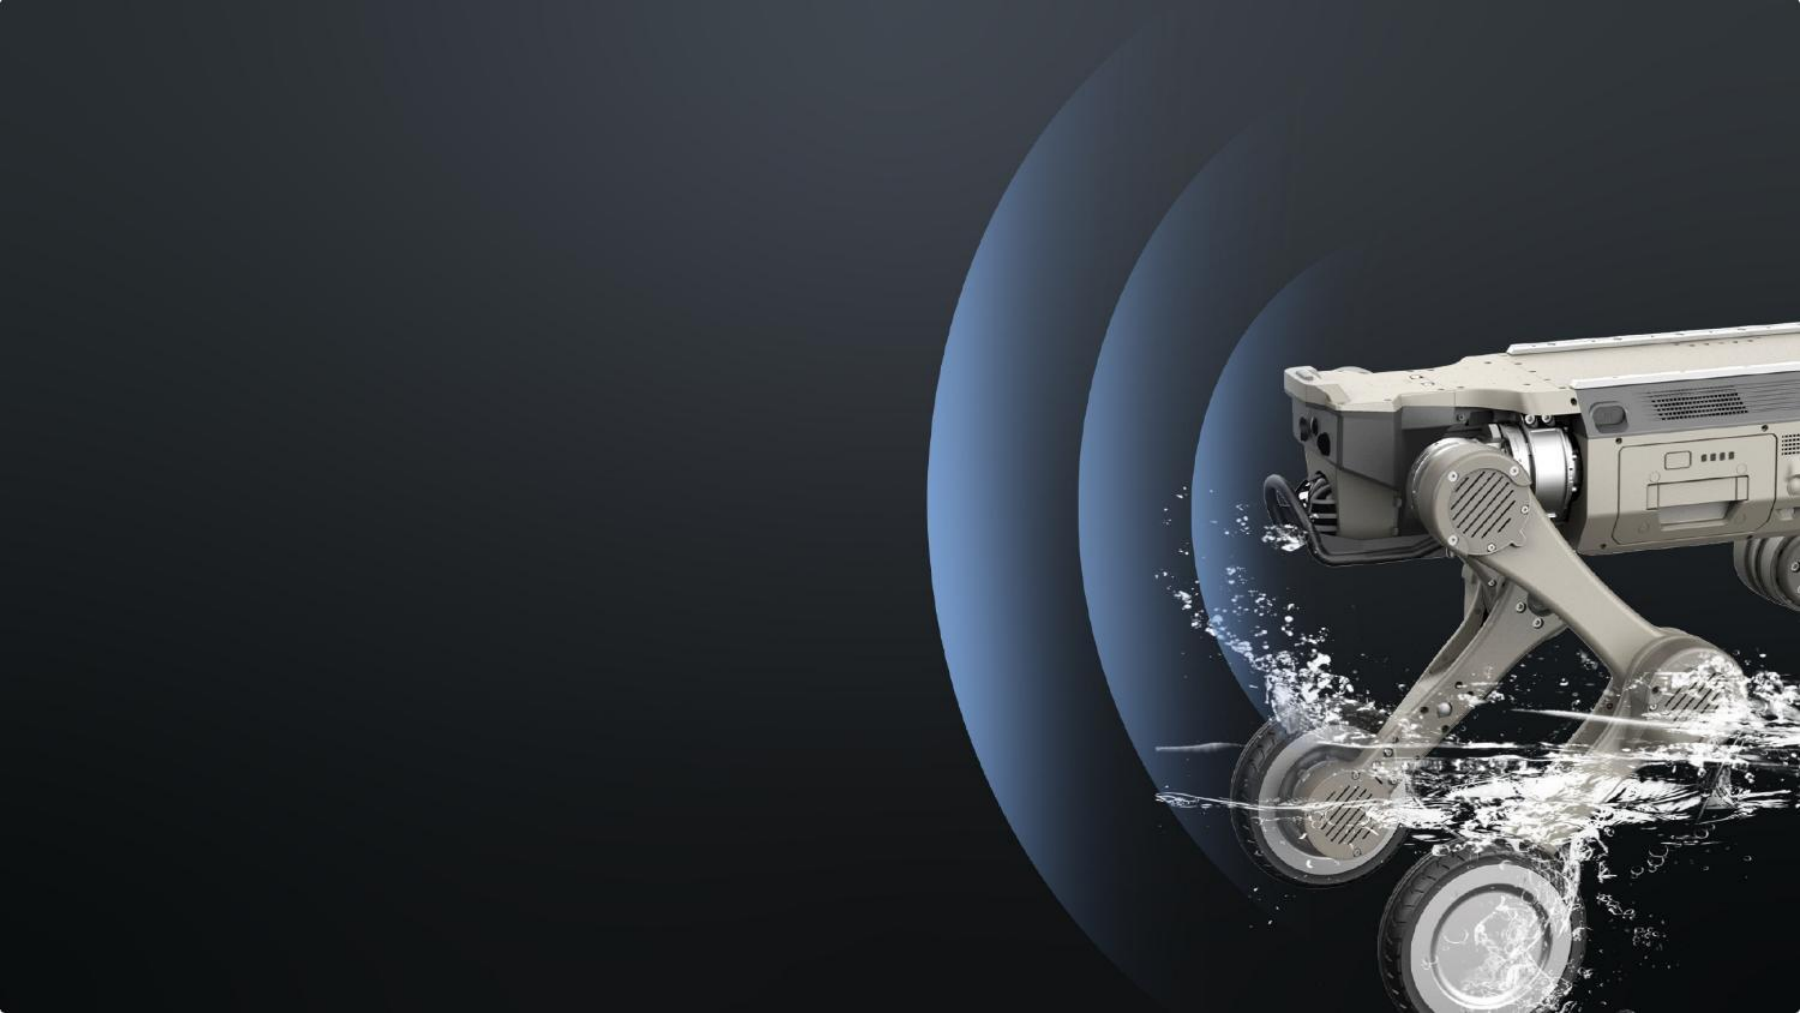
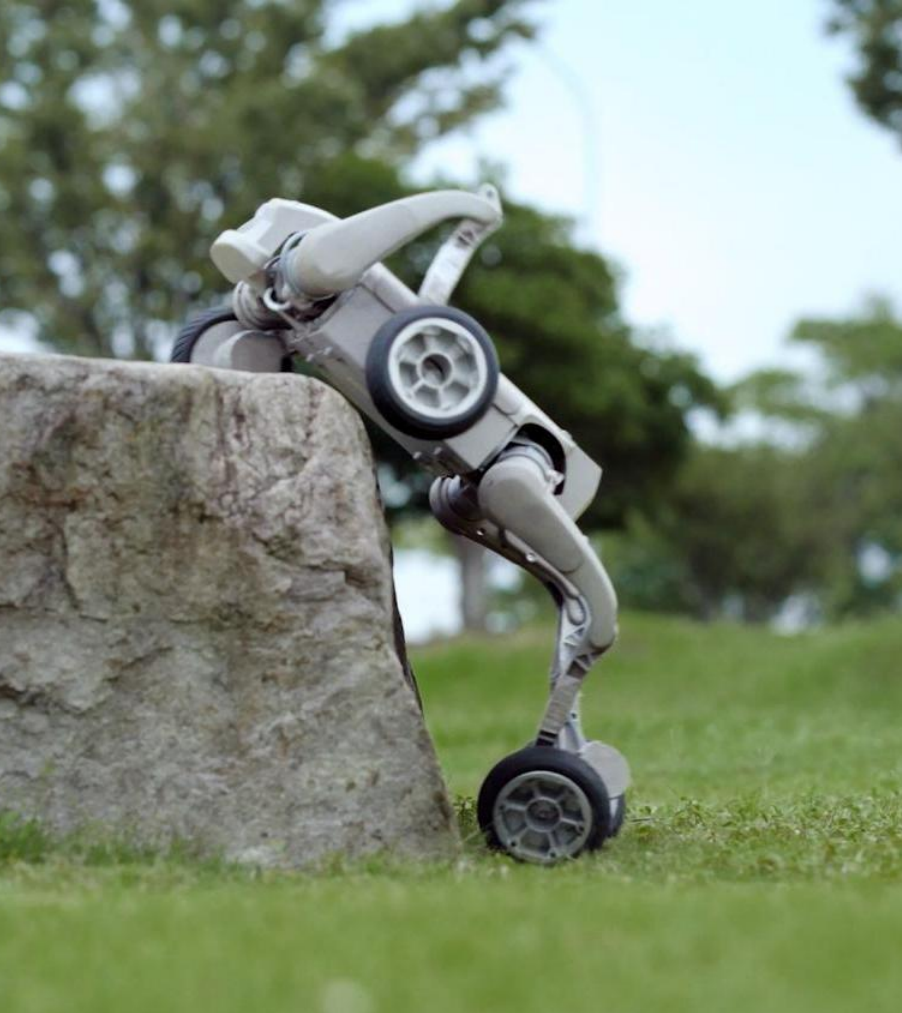
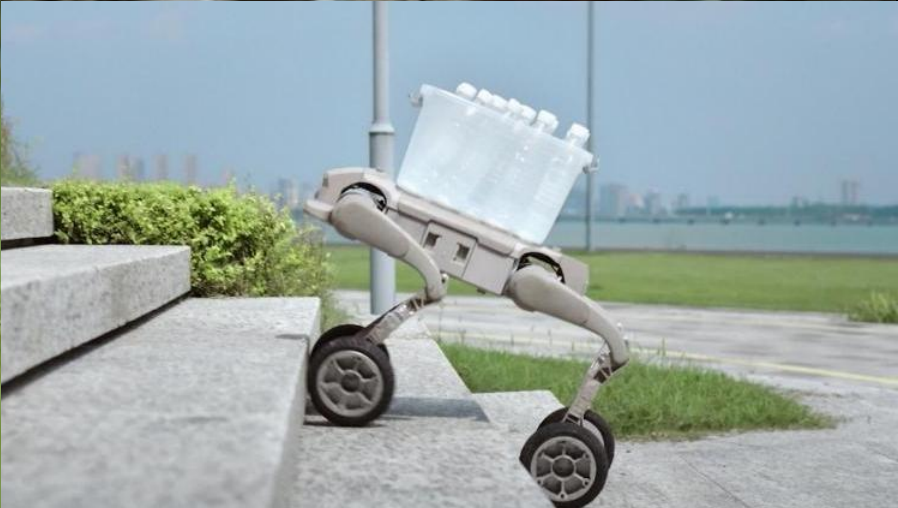
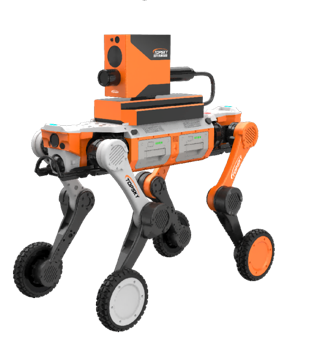
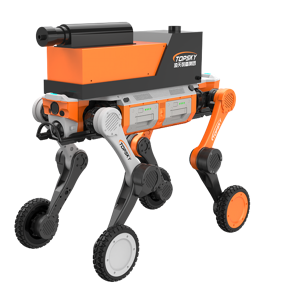
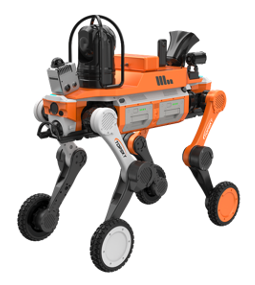
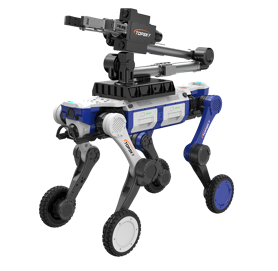
The first compact industrial wheeled quadruped

Wheels where speed pays off, legs where terrain gets serious. Seamless wheel-to-leg switching extends the reachable mission envelope.

Obstacle crossing
65 cm
Peak payload
12 kg
Range
9 km
Acoustics
Quiet low-noise operation
Max speed
3.7 m/s peak 5 m/s
Slope
40°
TCM01 lightweight high-payload quadruped robot
TCM01

Light body, heavy payload, fully protected

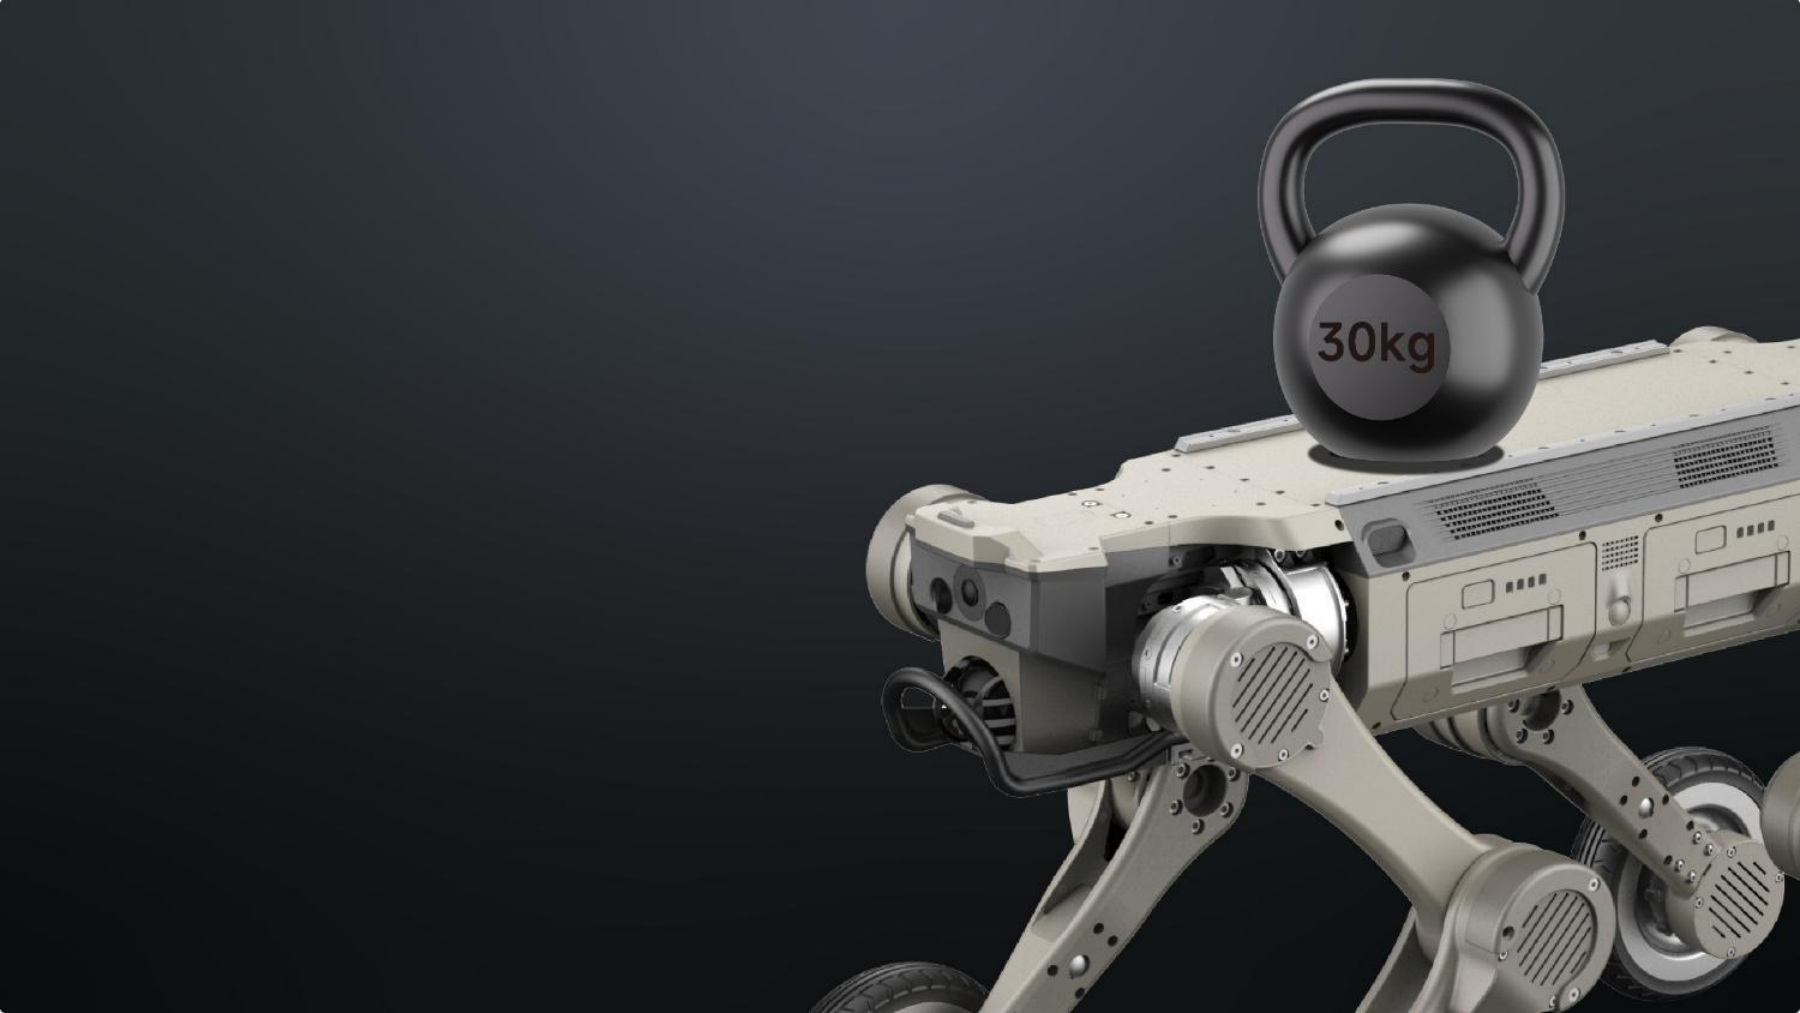
Near 1:1 payload-to-weight ratio with hot-swap dual batteries — missions continue while the pack is swapped, and the robot recharges itself.

Continuous payload
30 kg ≈1:1 with 35 kg body
Peak speed
8 m/s wheeled peak
Obstacle crossing
80 cm vertical
Slope
45°
Protection
IP67
Operating temp
−20 to 55 °C
Core components

Self-developed joint modules and hub motors

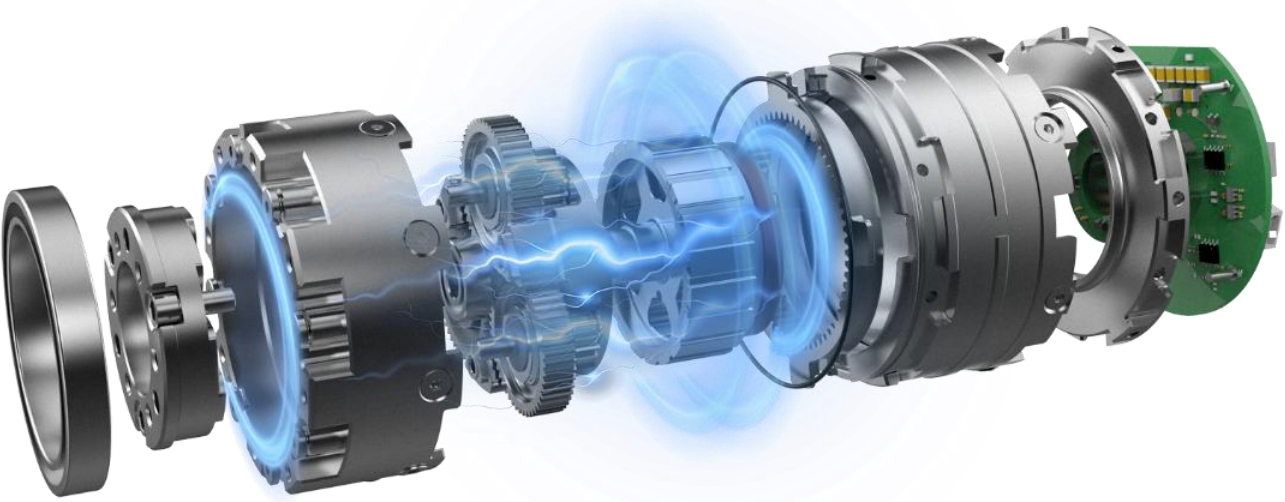
Integrated planetary reduction drive, dual encoders and driver, frameless torque motor and a die-cast aluminium housing. High power density, high reliability, lightweight packaging.

48 N·m peak torque

Planetary reduction drive delivering +50% peak torque versus comparable modules.

Dual encoder + drive

Fully integrated hardware design with dual-encoder feedback for precise, repeatable motion control.

Die-cast aluminium

High-strength, high-reliability housing machined for real industrial duty cycles.

High power density

Frameless torque motors and lightweight design keep torque high and mass low.

Exploded view of an integrated planetary joint module
Integrated joint and hub motor specifications
ModelODHGearboxPowerTorqueWeightBacklashVoltageEncoderIPTemp
P555750Planetary18120360≤2024–48DualIP54−20 to 50
P656560Planetary33048520≤2024–48DualIP54−20 to 50
P65MAX-S6561.6Planetary33075530≤2524–48DualIP67−20 to 50
P85MAX-S8567.9Planetary4401551000≤2024–60DualIP67−20 to 50
WHE150-S15059—43812.21150 incl. tyre—24–60SingleIP67−20 to 50
WHE190-S19086Planetary44033.151275 incl. tyre≤2024–60SingleIP67−20 to 50

Units — OD / H: mm · Power: W · Torque: N·m · Weight: g · Backlash: arcmin · Voltage: V · Temp: °C. Additional models in development.

Open platform & software

Open architecture, from sensor to data flywheel

An open platform architecture that adapts to any perception module — backed by a self-developed simulation platform and cloud operations software.

01

Modular expansion

Supports high-compute boards, perception and positioning modules, 4G and long-range video transmission modules.

02

Rich interfaces

Ethernet, USB, SBUS, UART and power ports, plus gigabit networking and multi-voltage power rails on the heavy platform.

03

Full SDK access

Motion interfaces, video-stream and status interfaces, and a fully open software SDK for deep secondary development.

MATRiX simulation

Precisely replicating real space

Our self-developed MATRiX open-source joint simulation platform converges virtual training with real deployment. It ingests LiDAR and depth-camera sensors, reuses the Unreal ecosystem's digital assets and 3DGS scene reconstruction, and speaks ROS 2 — collapsing both the cost and the cycle time of scenario construction.

Unreal digital assets 3DGS scene reconstruction ROS 2 interfaces LiDAR + depth sensing
Robot running at speed in simulation-like desert environment

Real → Sim → Real: the data flywheel

Products go to work, data comes in

Real deployments begin collecting operational data across every scenario.

Low-cost scene reconstruction

Captured environments are rebuilt in simulation at a fraction of the usual cost.

Strong physics simulation

Physics simulation and world-model refinement close the reality gap.

Deploy and re-collect

New policies ship to the fleet, which autonomously gathers the next data round.

AI reinforcement-learning locomotion

Standard RL algorithms ship on every robot: tens of millions of simulated data points and thousands of kilometres of field data train a control policy that keeps evolving.

High mobility · multiple skills Robust across terrain

Cloud operations software

Built for clustered patrol and monitoring: real-time 4-channel visible-light plus infrared thermal monitoring, video playback, task management and intelligent alarms.

Face / behaviour / vehicle recognition Env. data: temp, humidity, smoke, PM2.5 Fleet management
Autonomy

Single-agent competence, swarm-scale coordination

From tracking a single target to commanding an ultra-large-scale heterogeneous fleet.

SINGLE

Single-agent intelligence

Tracking, end-to-end learned navigation, and autonomous patrol with multimodal semantic scene recognition — the robot understands what it is looking at, not just where it is.

Target tracking End-to-end navigation Autonomous patrol Scene semantics
SWARM

Swarm intelligence

Ultra-large-scale clustering and heterogeneous collaboration, with multi-robot formation simulation and pursuit-tactic evolution developed in the MATRiX environment.

Large-scale clustering Heterogeneous collaboration Formation simulation Tactic evolution
Applications

Where the robots already work

Scaled deployment in security patrol, power inspection and emergency rescue — with the application boundary still expanding.

Power inspection
Security patrol
Emergency rescue
Mining patrol
Commercial service
Home companionship
Education & research
Guide-dog service
Community patrol
Logistics transport
Entertainment
Competitive gaming
Robot patrol on uneven ground

Police & security solution

Small patrol quadrupeds, medium security quadrupeds, fixed smart cameras, charging systems, communications and a backend management platform — combined into mobile video inspection, infrared temperature measurement and environmental monitoring for all-weather, all-direction autonomous patrol. Integrated into Safe City and Skynet programmes.

PatrolCounter-terror EODReconnaissanceEvidence capture
Robot during a power inspection mission

Power inspection

Intelligent inspection, procedural execution and unmanned operation, with faults identified and escalated the moment they appear.

Jiuquan Satellite Launch Center Shanxi power grid Wuxi substation
Quadruped robot patrolling a public park

Security patrol deployments

Intelligent patrol with real-time hazard capture.

Historic town, SuzhouCoastal scenic areaLarge public park
Robot assisting a user along city steps

Guide-dog service

Assistive navigation for visually impaired users in daily environments.

Assistive mobilityDaily environments
Robot moving at speed

Mining patrol

Rugged-terrain patrol and inspection across industrial sites.

Rugged terrainIndustrial sites

Payload & upper-attachment options

Laser breaching attachment

Laser breaching

Quadruped-mounted
Electric water-mist attachment

Electric water mist

Quadruped-mounted
Assisted reconnaissance attachment

Assisted reconnaissance

Quadruped-mounted
Hazardous material disposal attachment

Hazardous material disposal

Quadruped-mounted
Pulse firefighting Assisted firefighting Inert gas firefighting Power inspection payloads
Specifications

Quadruped series full specifications

Dimensions
Standing size (L × W × H)≈63 × 36 × 41.5 cm
Crouched size (L × W × H)≈67 × 42.5 × 14.5 cm
Weight
Curb weight (incl. battery)≈15 kg
Battery
Nominal capacity5 Ah, 43.2 V
Endurance
Runtime1–2 h
Range6 km
Payload
Continuous walking payload≈8 kg (peak ≈10 kg)
Mobility
Running speedMax 3.7 m/s (peak 5 m/s)
Obstacle crossing height—
Continuous stair climbing>16 cm
Slope walking30° standard, up to 40° peak
Environment
Operating temperature0 °C to 40 °C
Ingress protectionIP54
Interfaces
Expansion portsEthernet, USB, SBUS, UART, power

Specifications are for reference and may vary by configuration. Additional joint and hub-motor models are in development.